L3Flight application
VAYU
The aircraft itself — reading its sensors, estimating attitude, running the control loops, driving the motors.
- Cascaded PID
- 1 kHz / 250 Hz loops
- Fail-safe recovery
One runtime, built from the silicon up — from the register NavHAL writes to, up to the aircraft VAYU flies.
Free board for the first 50 college students.
Four layers, all ours
Read it top to bottom. Each layer is ours, so each one can be opened, measured and replaced without asking anybody.
“We are not building another autopilot. We are building the foundation: a sovereign, silicon-native runtime that belongs entirely to its operator. No black boxes. No foreign dependencies. Just pure, auditable control.”
Recognised by


Products
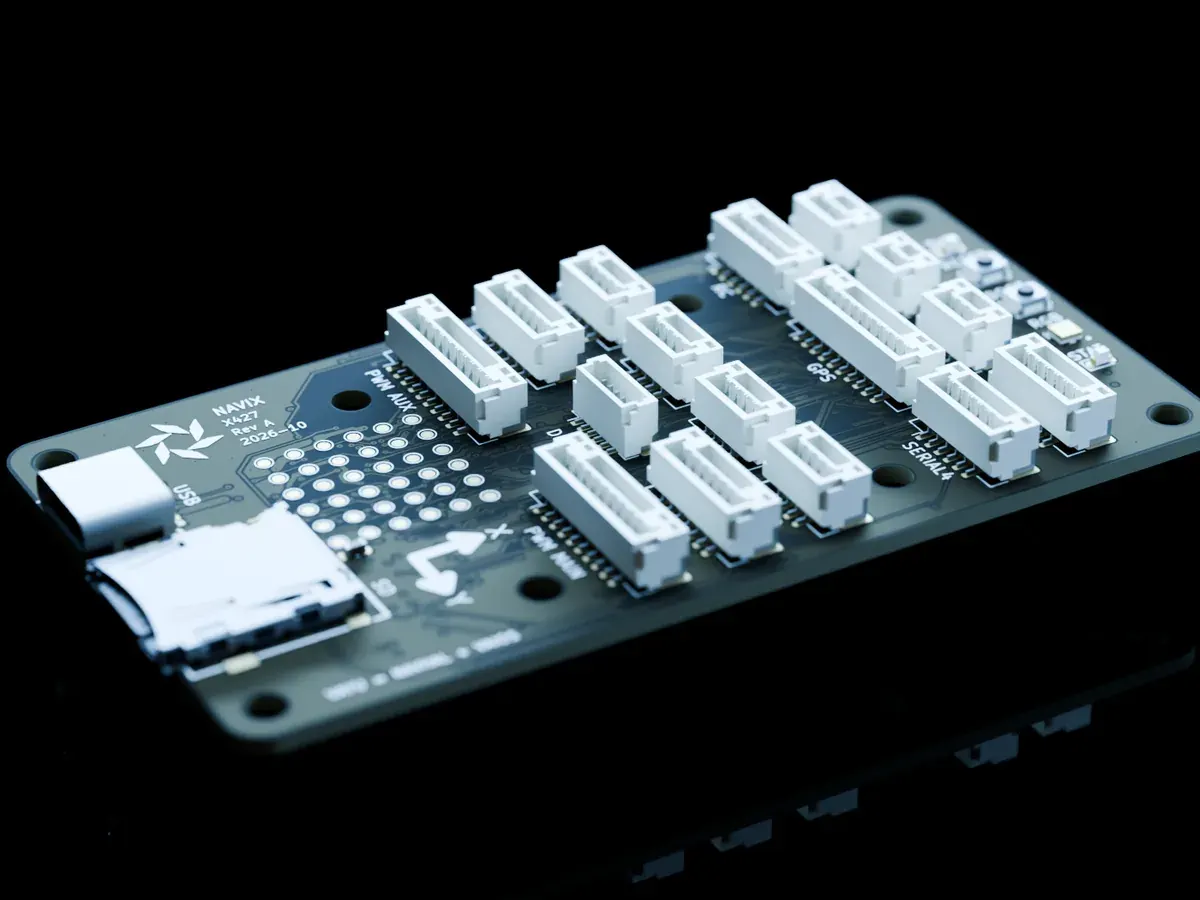 Flight controller · Rev A
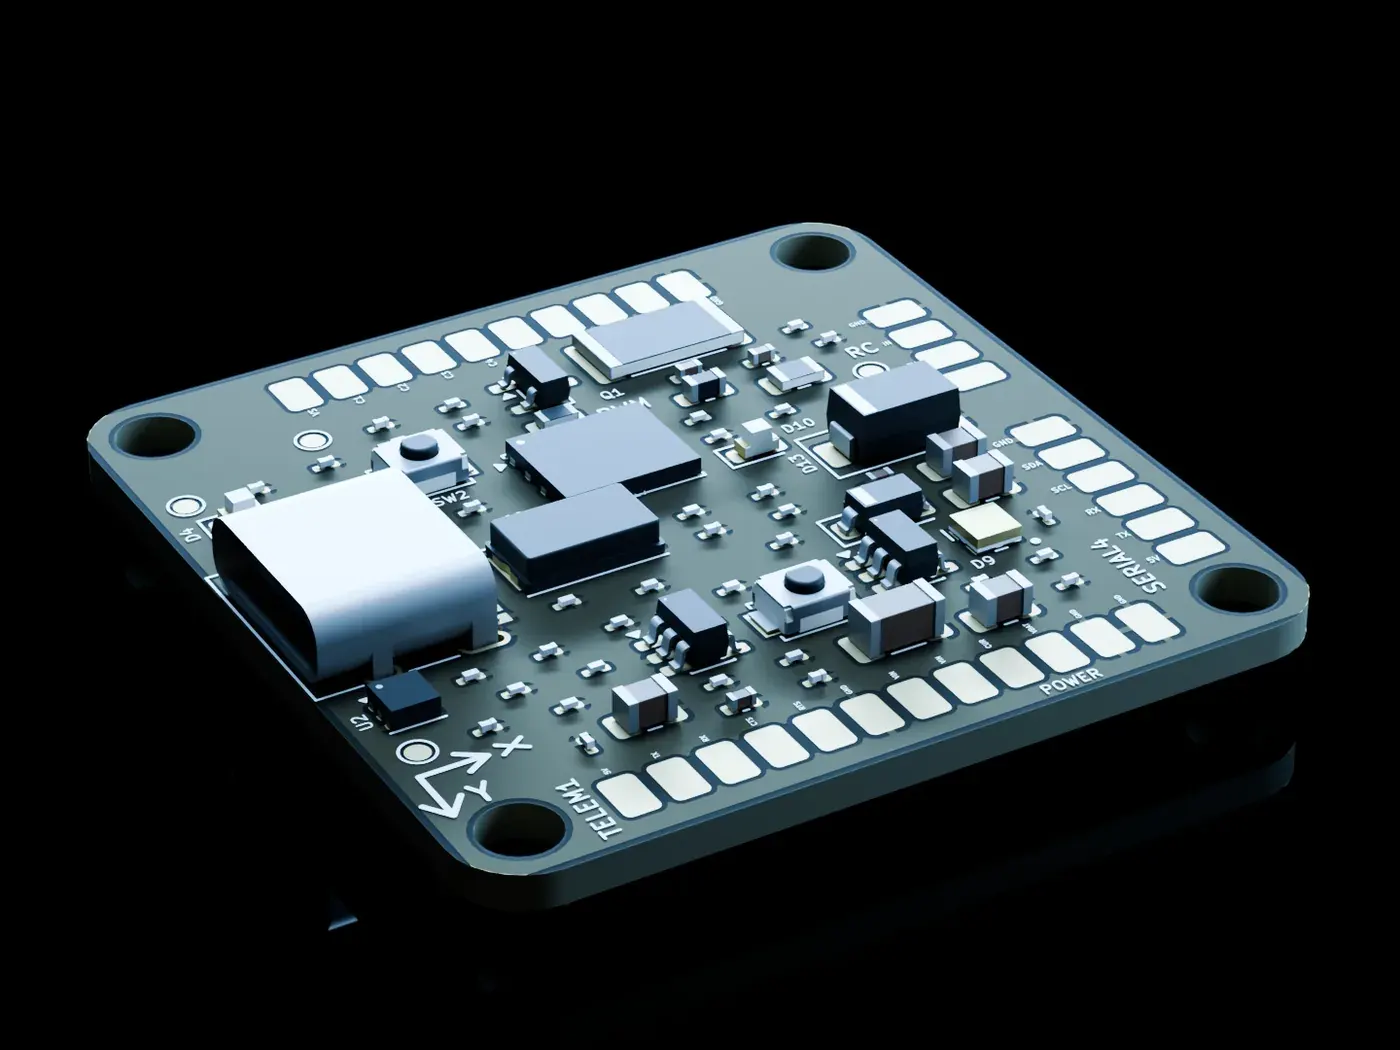 Flight controller · In design
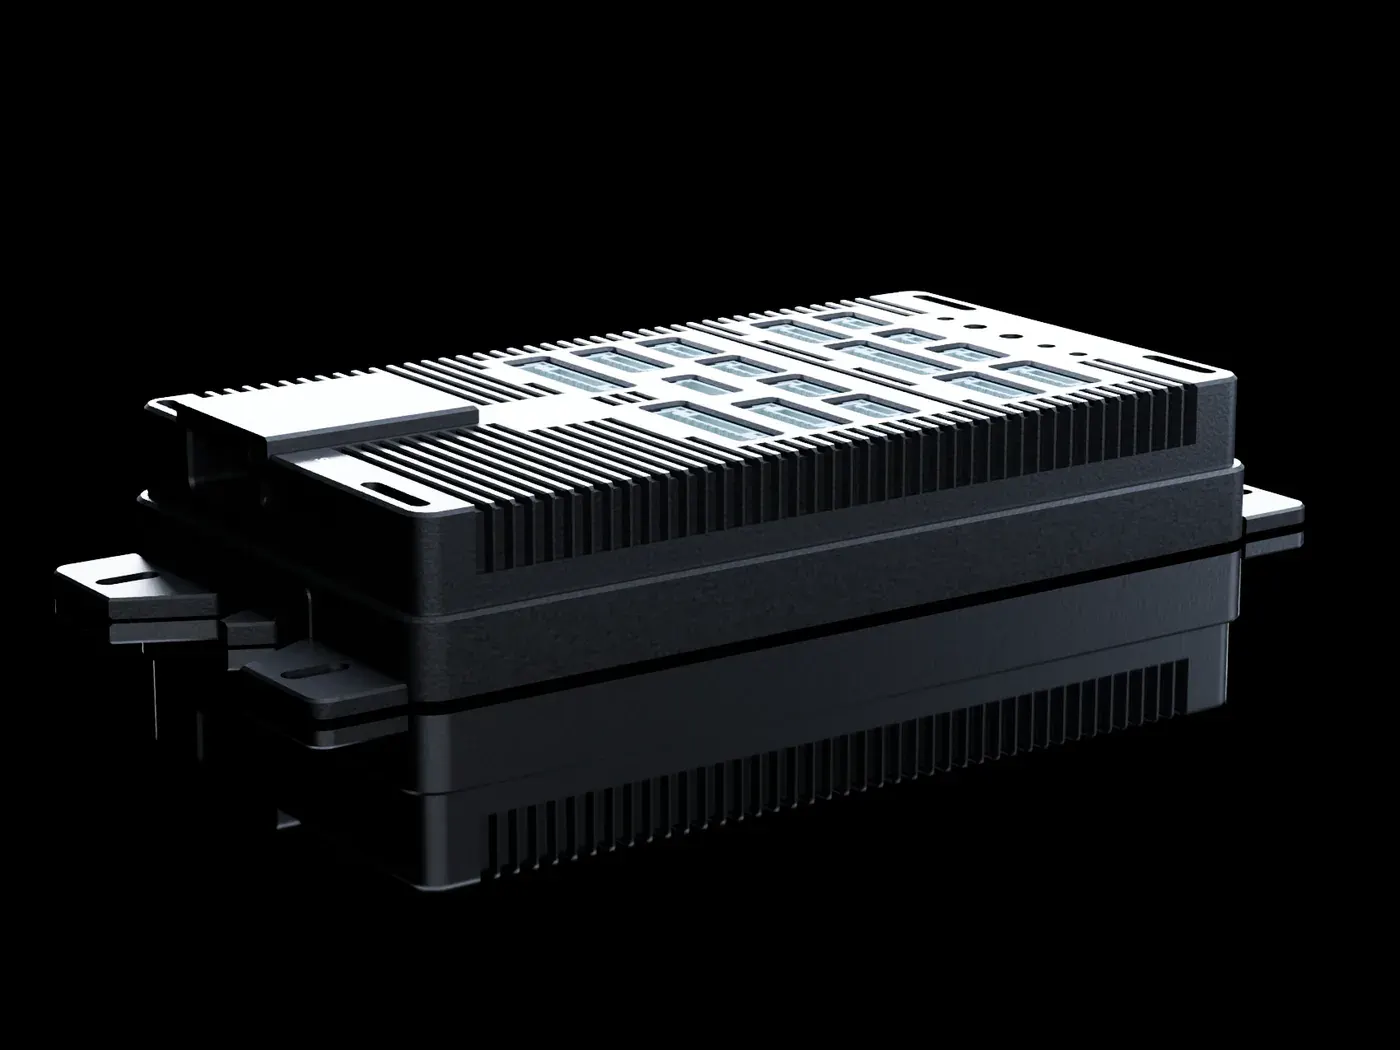 Enclosure · In design
Flight tests


Join the mission
Contribute to the core layers of VaiOS, from NavHAL up. Build on a stack you can read, audit and extend down to the register.
Read the docsCo-develop custom hardware, or join the pilot programme to put a sovereign runtime in your fleet.
Talk to usBack the work of taking high-grade autonomous navigation out of foreign black boxes and into something auditable.
The caseNext
The per-layer guides and the benchmarks against FreeRTOS and Zephyr are all public. Start there — or write to us about putting the runtime in your fleet.